3D Bin Picking Automates Plastic Part Handling
Case Overview
Industry: Manufacturing, Petrochemicals, Plastics, & Rubber
Solution: AccuPick
A sanitary equipment manufacturer implemented Solomon’s AccuPick 3D bin picking solution to automate the transfer of plastic parts from bins to a rotating carousel for downstream threading operations.
The Case
Automating Part Transfer Before Threading
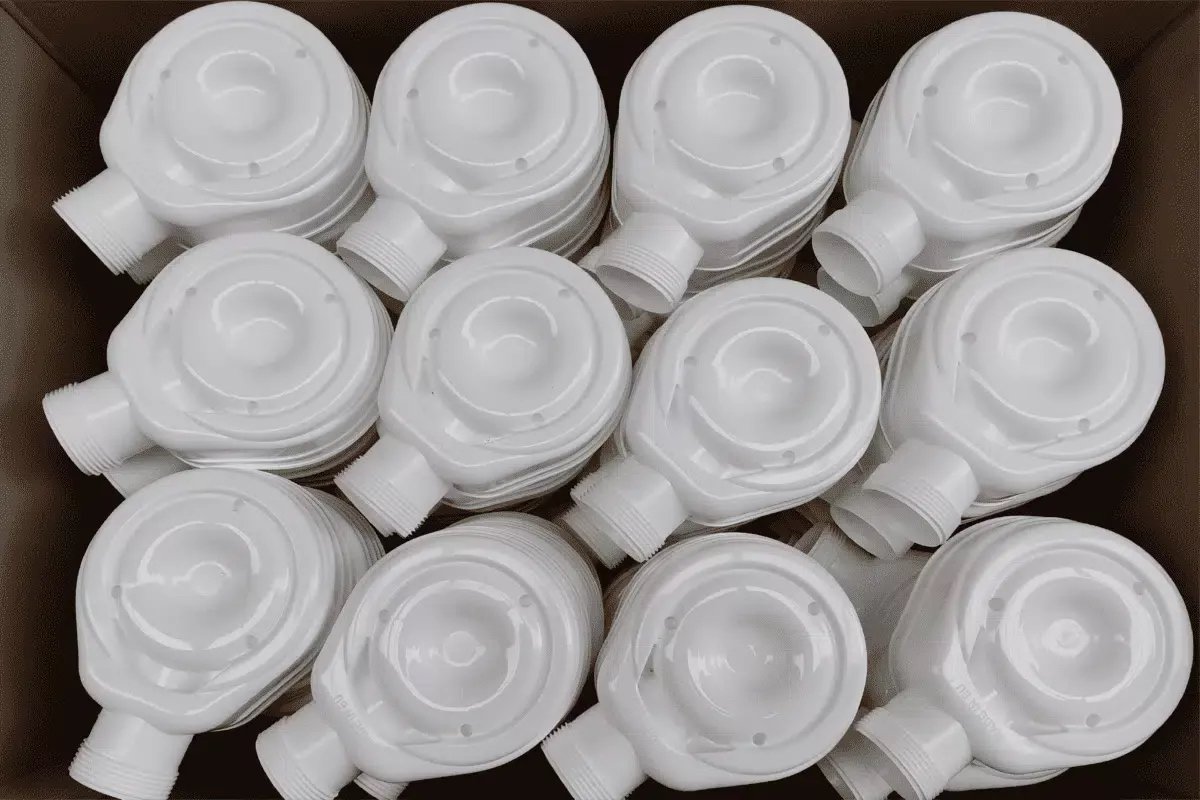
The customer produces and supplies sanitary equipment to markets across Europe. As part of its production process, plastic parts must be removed from bins and placed onto a rotating carousel, where a separate machine creates threads in the parts for bolts.
The manual process caused production interruptions between part picking and the downstream threading operation, creating a need for automated part transfer.
The Challenge
Identifying Accurate Picking Points in Semi-Structured Bins
The plastic parts were arranged in a semi-structured layout inside the bin, requiring the system to identify suitable picking positions before each transfer.
Because part positions could change between picking cycles, the customer required a 3D bin picking system capable of determining accurate picking points and supporting consistent robot handling.
Manual handling could not provide the automated picking and transfer required for continuous integration with the downstream threading process.
The Solution
AccuPick 3D Bin Picking with SolScan
Solomon integrated AccuPick bin picking software with the SolScan industrial 3D camera and a Universal Robots UR10 cobot.
At the beginning of each picking cycle, SolScan captured 3D image data of the parts in the bin. AccuPick used this information to update part positions and determine appropriate robot picking points based on the current arrangement.
The UR10 cobot then picked the identified plastic part and transferred it to the rotating carousel for the subsequent threading operation. Repeating the imaging and position-calculation process each cycle enabled AccuPick to account for changes in part location within the semi-structured bin.
Plastic Part Bin Picking and Transfer
The automated workflow combined 3D scanning, picking-point identification, and robotic handling to move plastic parts from the bin to the carousel. The transferred parts could then proceed to the separate threading machine for bolt preparation.